Sungwon Seo
I am a Ph.D. candidate in the Robotics and Intelligent System Engineering Lab (RISE LAB) at Sungkyunkwan University, supervised by Prof. Hyungpil Moon.
My research interests lie broadly in robot learning and robotic manipulation. I am particularly interested in learning-based approaches to robot policy learning, including imitation learning, reinforcement learning, and vision-language-action models.
Publications
You can also find my articles on Google Scholar.
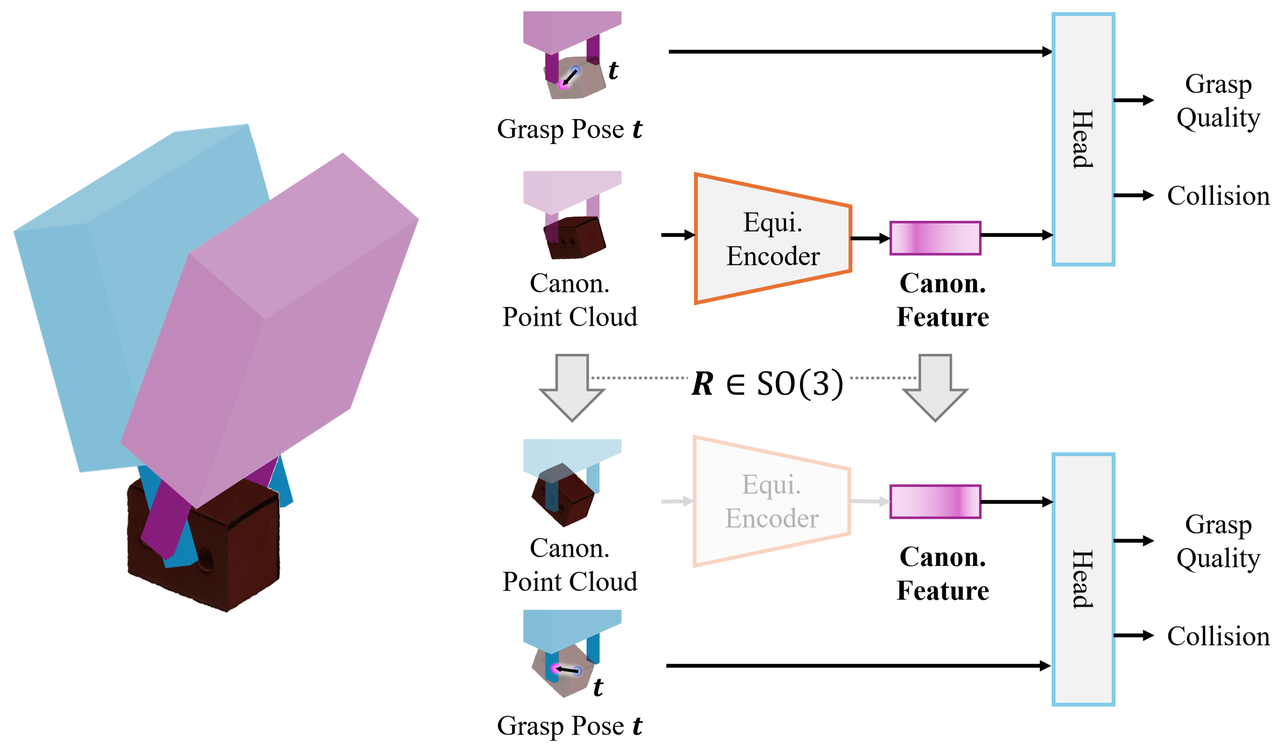
EquiGQNet: Fast Grasp Quality Evaluation via Shared Equivariant Point Cloud Encoding
Sungwon Seo, Jaeseog Won, Jiyou Shin, Youngjin Seo, Hyunjun Kim, Seokmin Yoon, Tuan Luong, Hyungpil Moon
arXiv:2609.07145, 2026 (preprint)
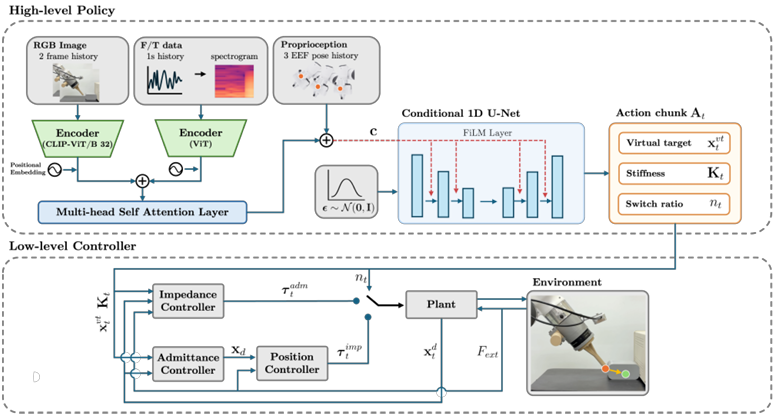
URF: A Unified Robot Control-Policy Framework for Stable Contact Aware Manipulation
Jiyou Shin, Youngjin Seo, Jaeseog Won, Sungwon Seo, Hyunjun Kim, Seokmin Yoon, Tuan Luong, Hyungpil Moon
arXiv:2607.20912, 2026 (preprint)
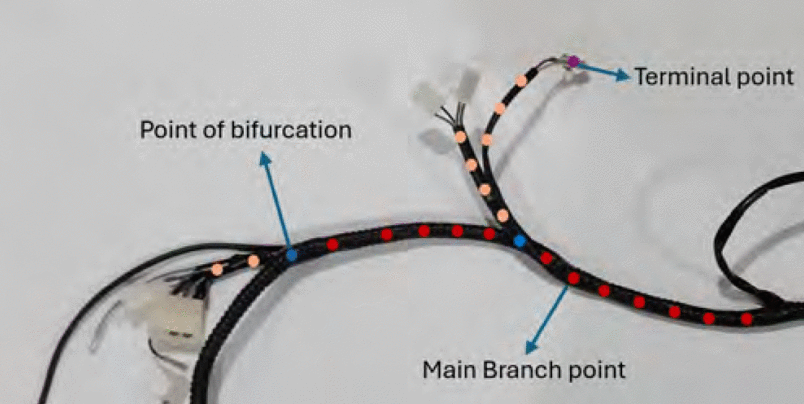
Grip points generation on motorcycle wire harnesses main branch based on computer vision and clustering
Sofia Espana, Juan Sanchez, Carlos Saldarriaga, Bryan Puruncajas, Sungwon Seo, Hyungpil Moon, Francisco Yumbla
2024 10th International Conference on Automation, Robotics and Applications (ICARA), 2024
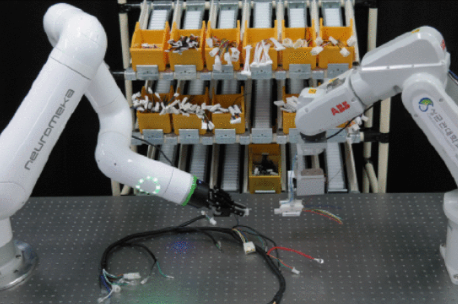
Wire harness connectors mating process by dual-arm co-manipulation using maximum manipulability
Francisco Yumbla, Juan Medrano, Tuan Luong, Sungwon Seo, Jeongmin Jeon, Hyungpil Moon
2023 IEEE 19th International Conference on Automation Science and Engineering (CASE), 2023
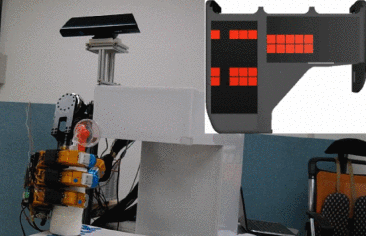
Design and Fabrication of an Array of Touch Sensors for Robotic Applications
Tuan Luong, Sungwon Seo, Jeongmin Jeon, Chanyong Park, Myeongyun Doh, Sanghyun Park, Francisco Yumbla, Hyungpil Moon
2023 IEEE 19th International Conference on Automation Science and Engineering (CASE), 2023
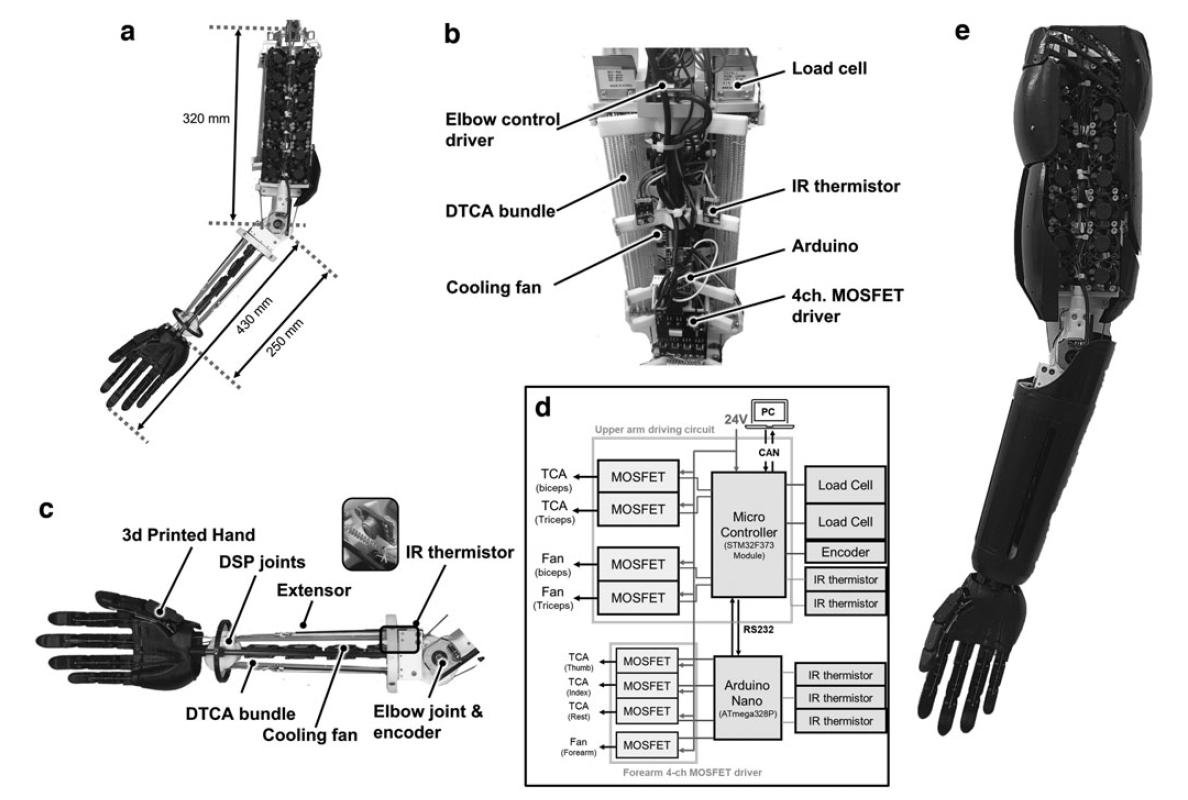
Design and control of lightweight bionic arm driven by soft twisted and coiled artificial muscles
Sang Yul Yang, Kihyeon Kim, Jeong U Ko, Sungwon Seo, Seong Taek Hwang, Jae Hyeong Park, Ho Sang Jung, Young Jin Gong, Ji Won Suk, Hugo Rodrigue, et al.
Soft Robotics, 2023
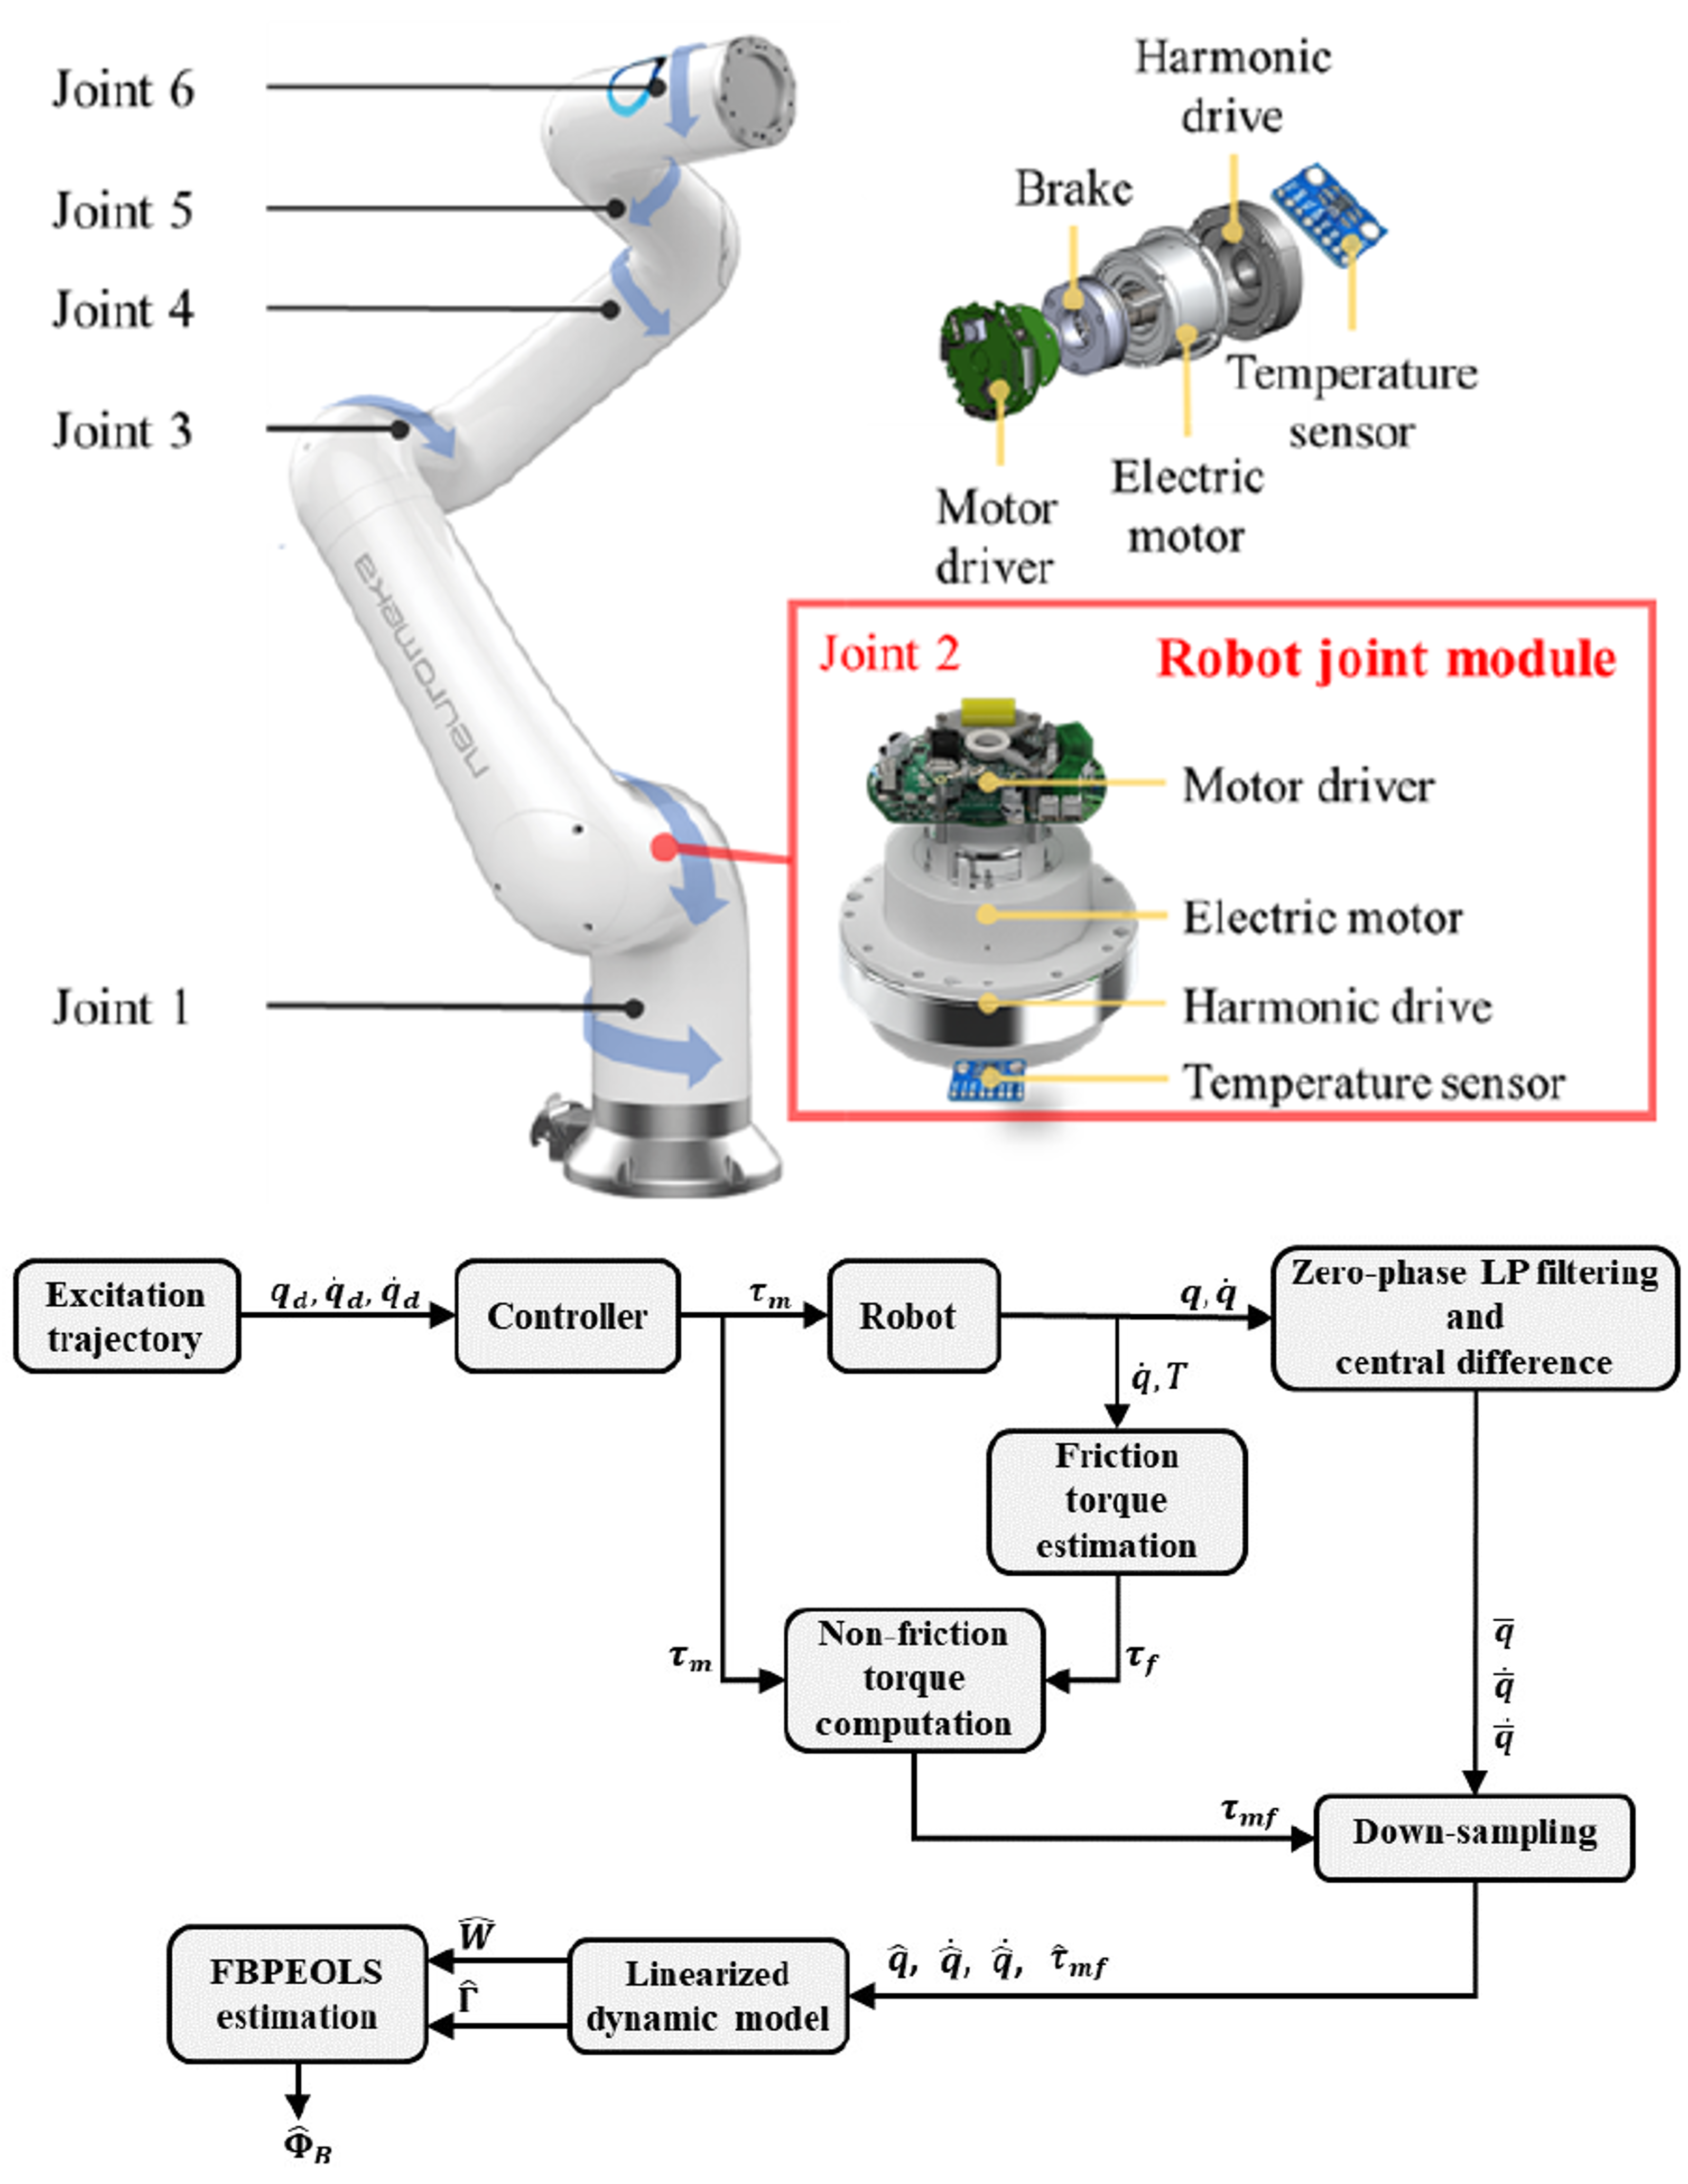
A two-step method for dynamic parameter identification of indy7 collaborative robot manipulator
Meseret Tadese, Nabih Pico, Sungwon Seo, Hyungpil Moon
Sensors, 2022
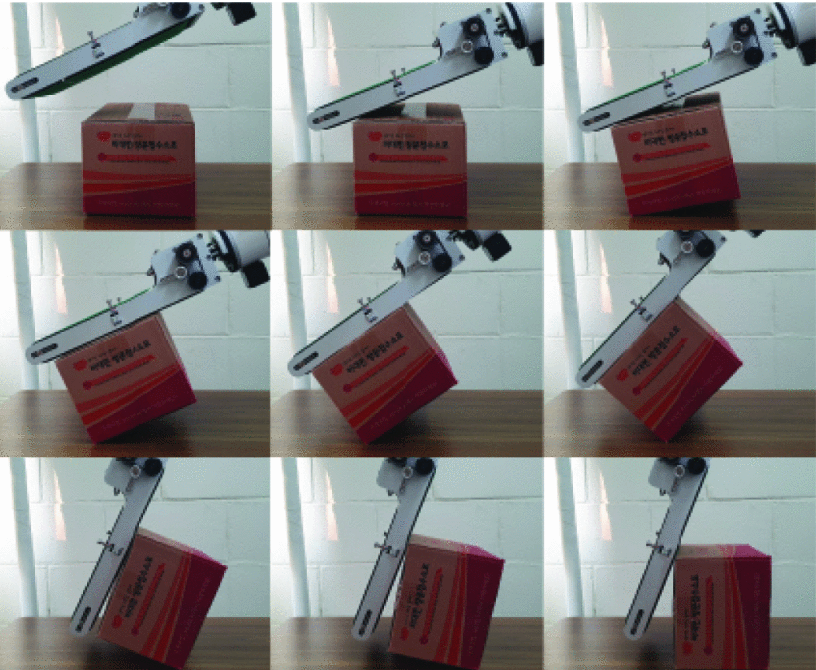
Design of a Conveyor Belt Manipulator for Reposition of Boxes in Logistics Centers
Francisco Yumbla, Juan Medrano, Edwin Valarezo, Hong-Ryul Jung, Tuan Luong, Sungwon Seo, Jinjae Shin, Hyungpil Moon
2022 IEEE 18th International Conference on Automation Science and Engineering (CASE), 2022
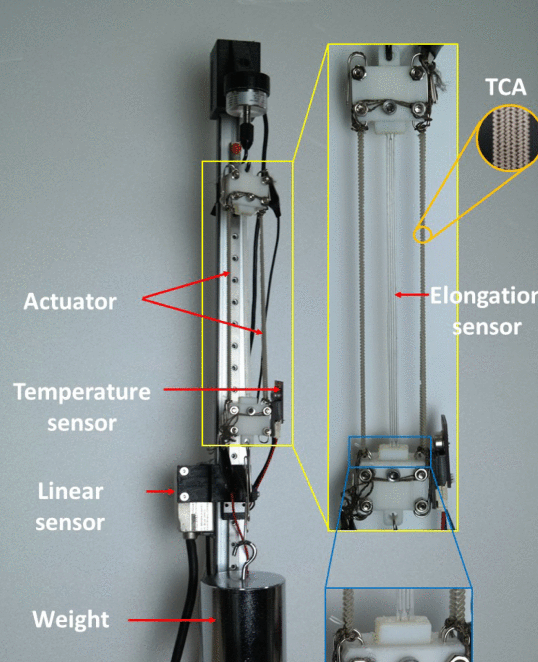
Soft artificial muscle with proprioceptive feedback: design, modeling and control
Tuan Luong, Sungwon Seo, Jeongmin Jeon, Chanyong Park, Myeongyun Doh, Yoonwoo Ha, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
IEEE Robotics and Automation Letters, 2022
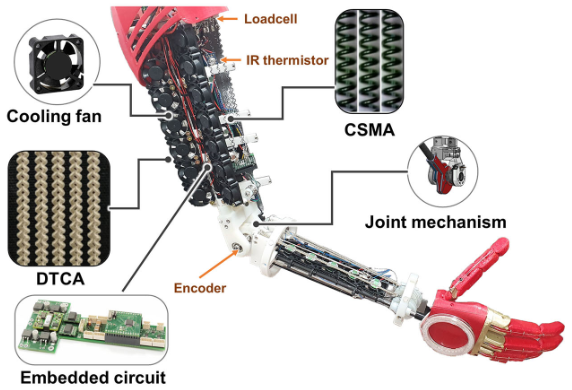
Hybrid antagonistic system with coiled shape memory alloy and twisted and coiled polymer actuator for lightweight robotic arm
Sang Yul Yang, Kihyeon Kim, Sungwon Seo, Dongsu Shin, Jae Hyeong Park, Young Jin Gong, Hyouk Ryeol Choi
IEEE Robotics and Automation Letters, 2022
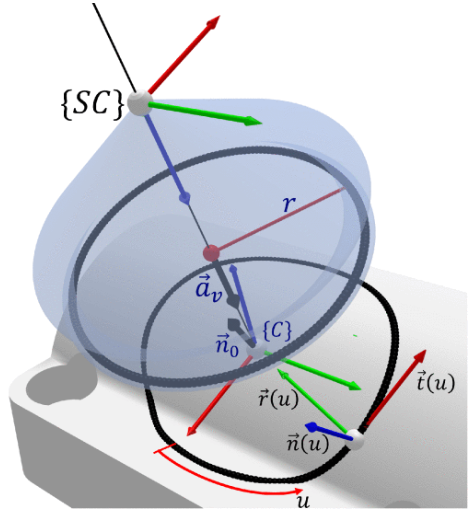
Vacuum suction cup modeling for evaluation of sealing and real-time simulation
Jure Hudoklin, Sungwon Seo, Minseok Kang, Haejoon Seong, Anh Tuan Luong, Hyungpil Moon
IEEE Robotics and Automation Letters, 2022
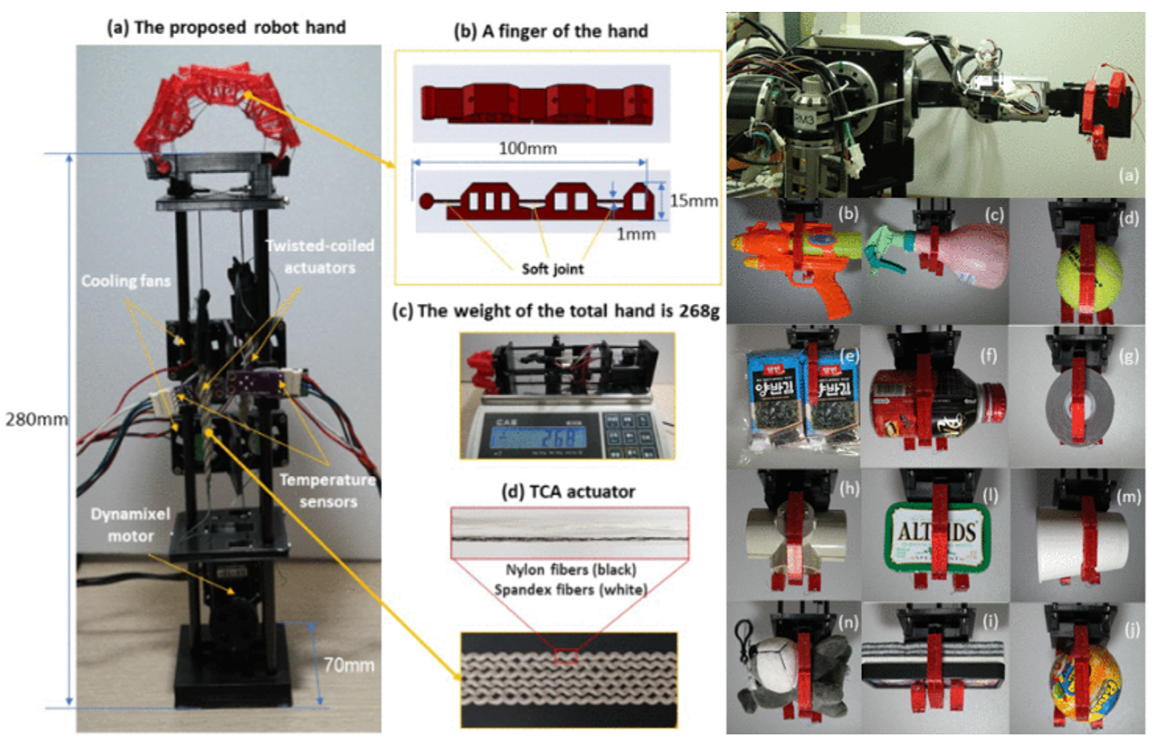
Variable stiffness robotic hand driven by twisted-coiled polymer actuators
Tuan Luong, Sungwon Seo, Jure Hudoklin, Ja Choon Koo, Hyeok Ryoul Choi, Hyungpil Moon
IEEE Robotics and Automation Letters, 2022
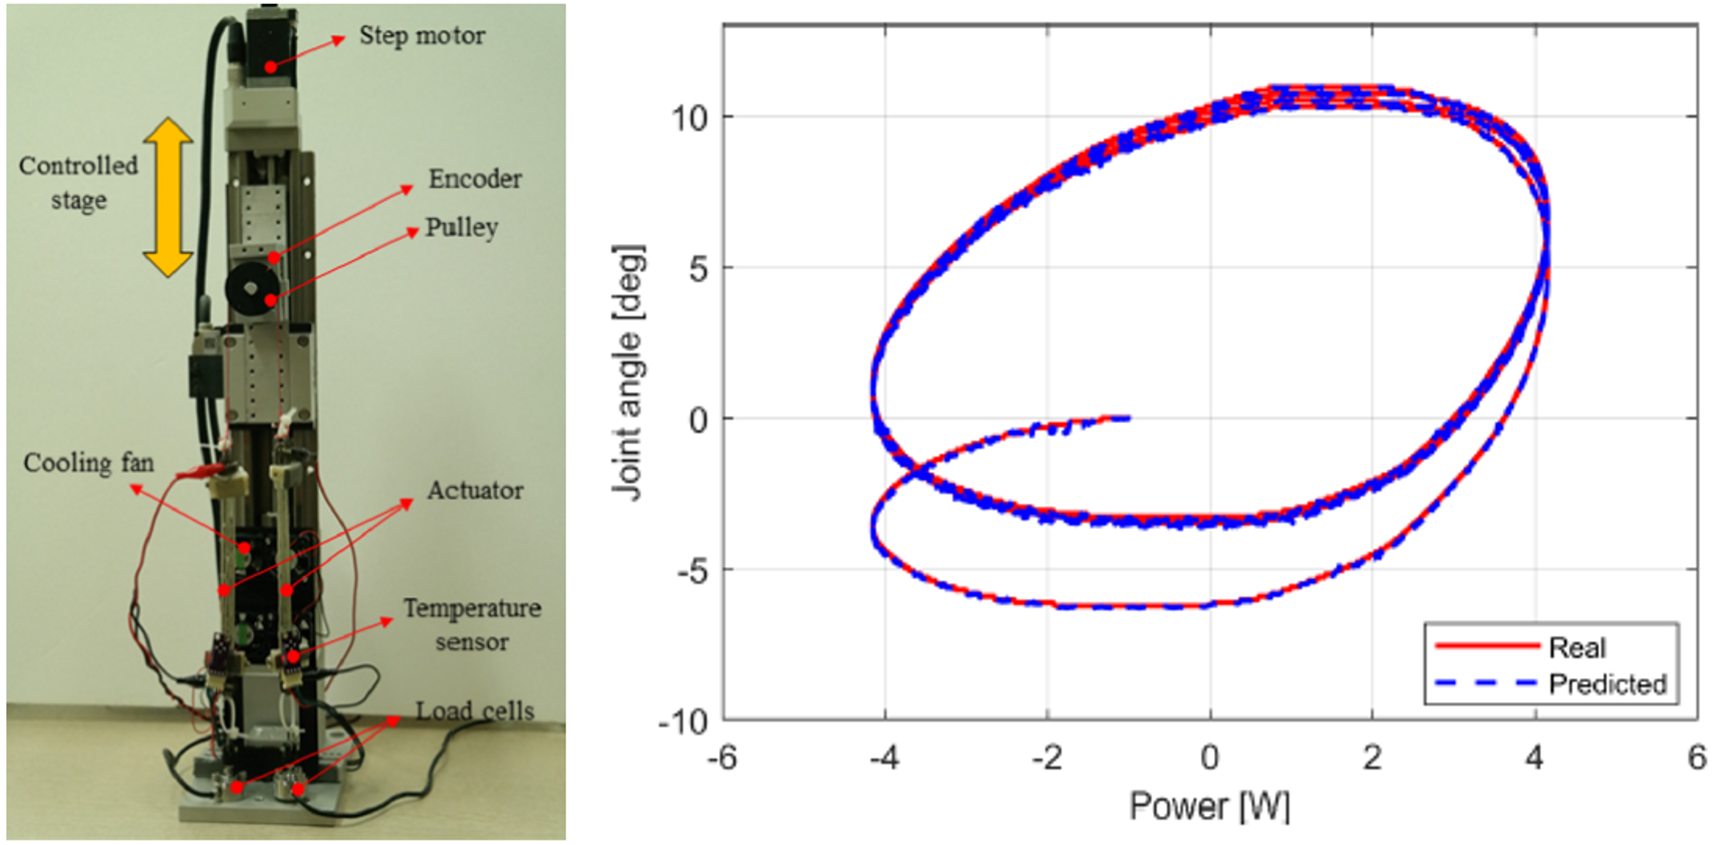
Hysteresis modeling of twisted-coiled polymer actuators using long short term memory networks
Tuan Luong, Sungwon Seo, Kihyeon Kim, Jeongmin Jeon, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
IFToMM Asian Conference on Mechanism and Machine Science, 2021
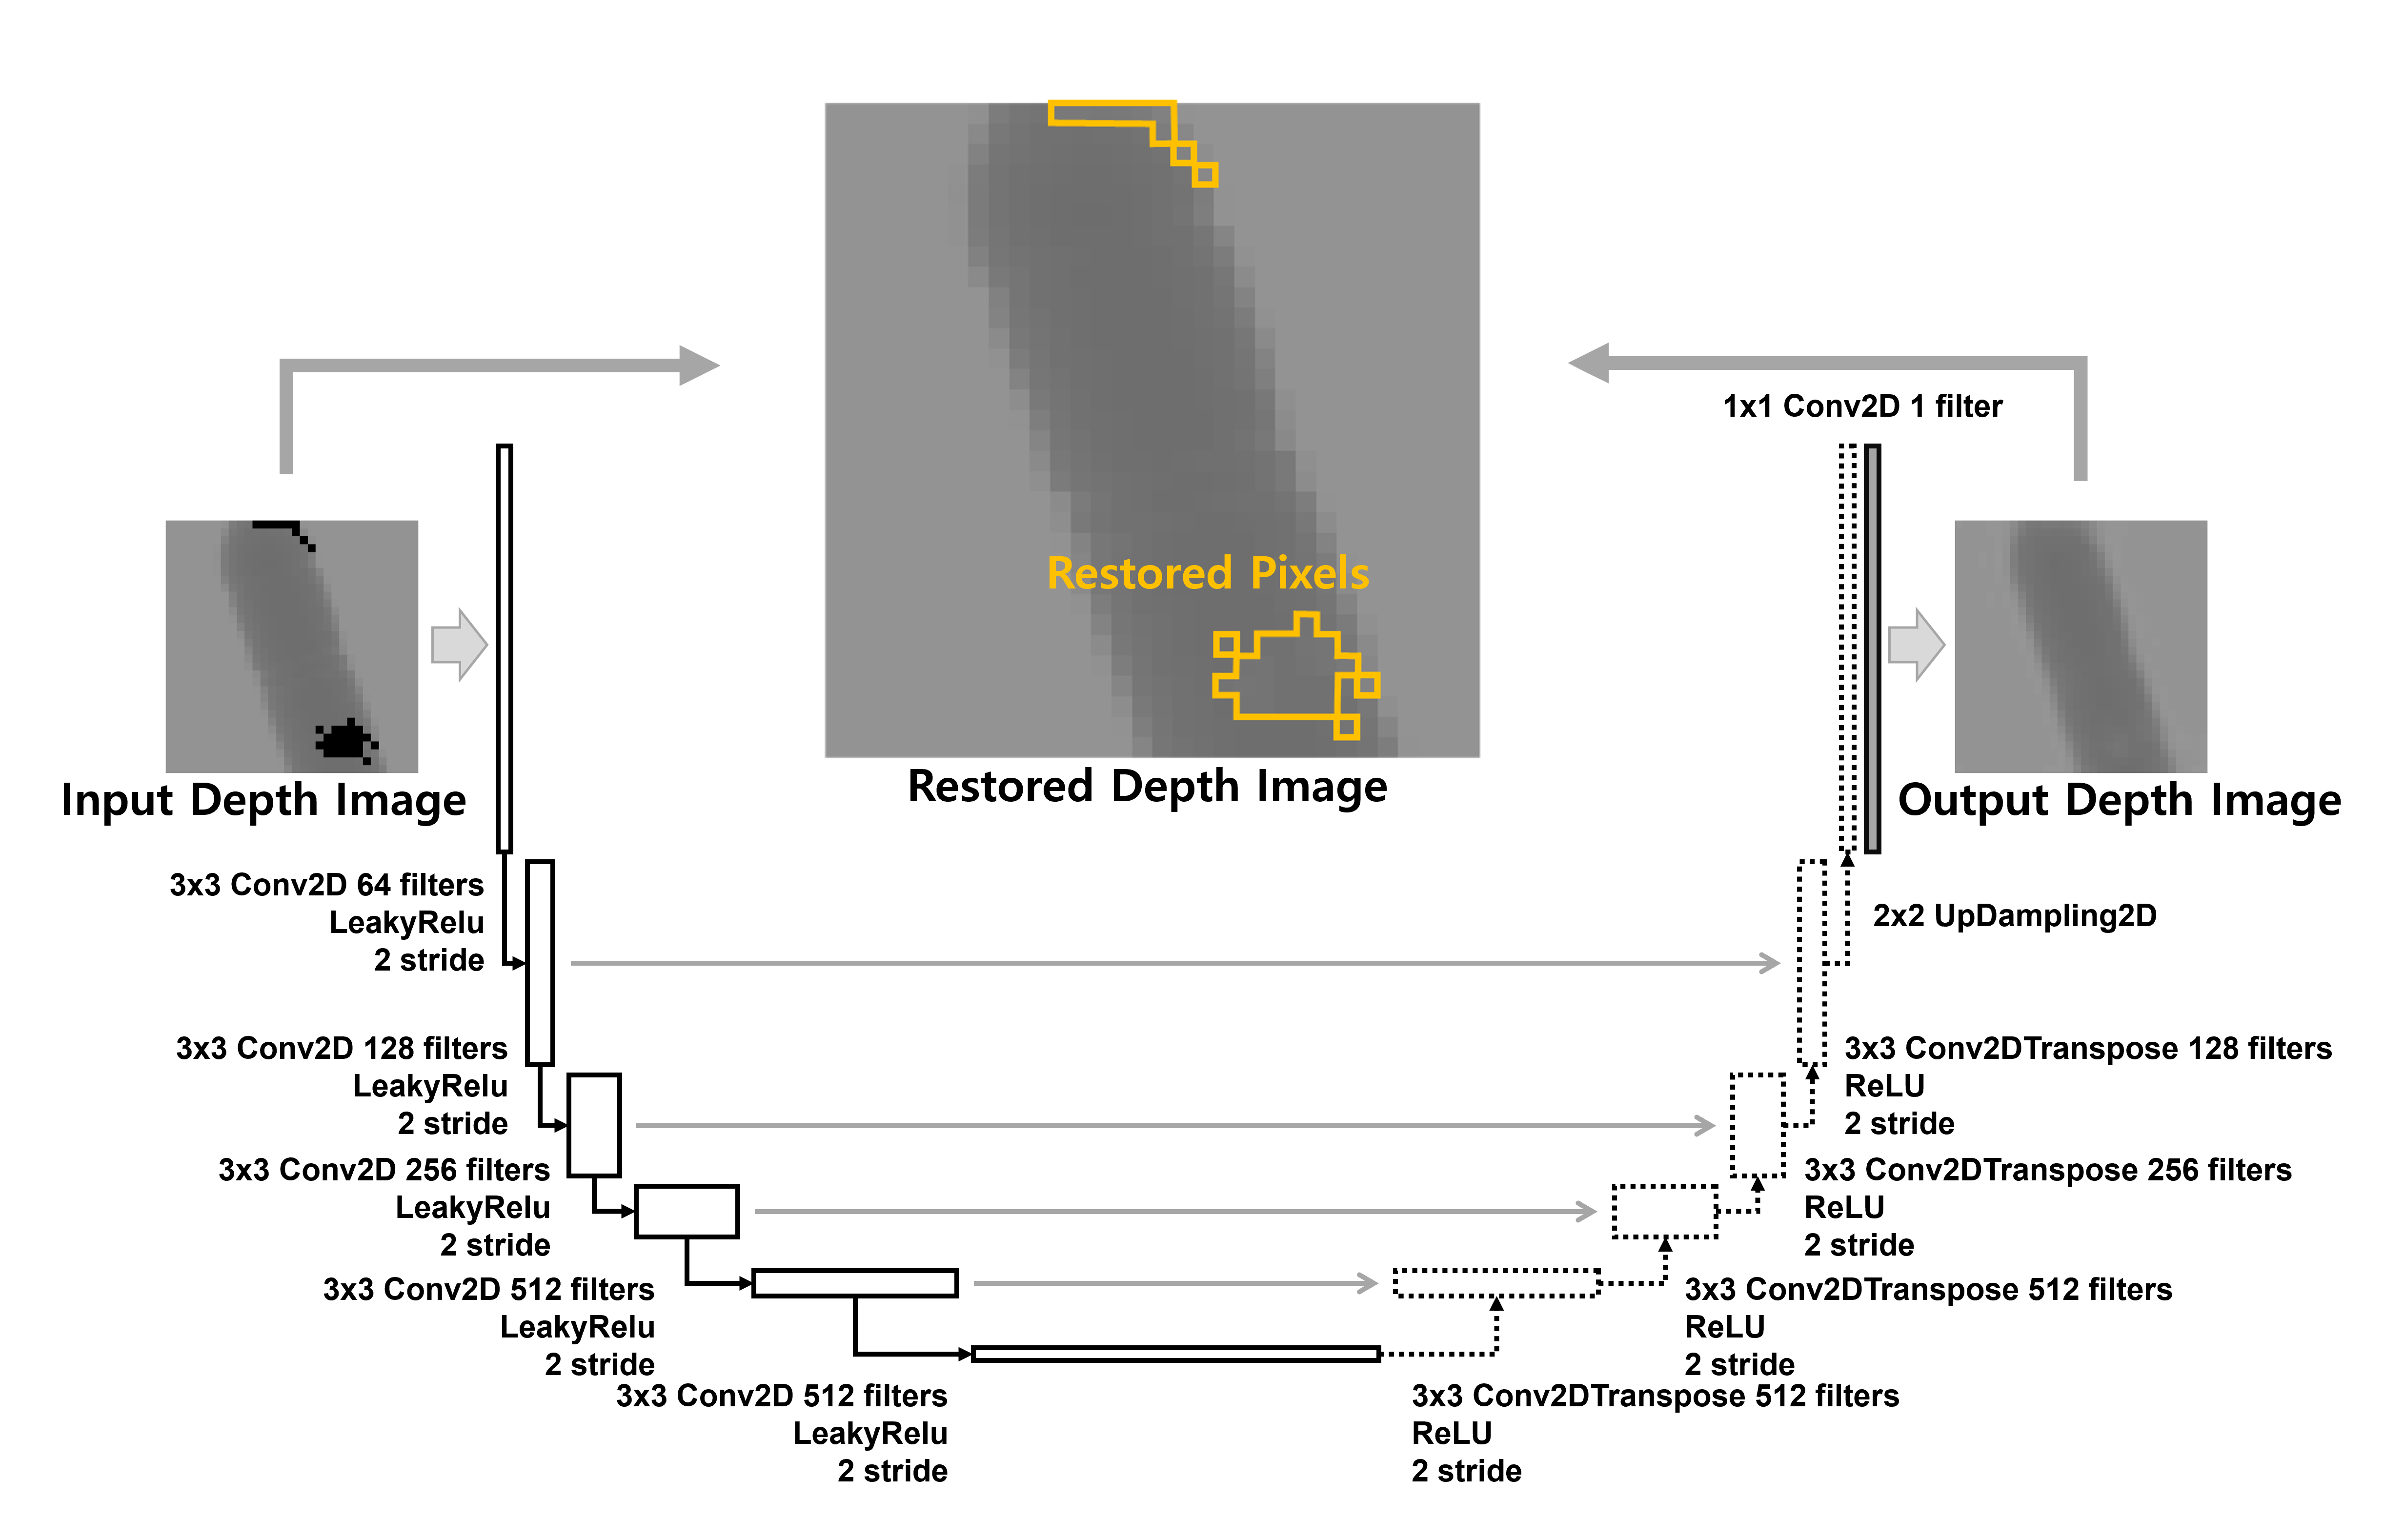
Depth hole filling based on deep learning for robust grasp detection
Sungwon Seo, Luong Anh Tuan, Eugene Auh, Hyungpil Moon
2021 18th International Conference on Ubiquitous Robots (UR), 2021
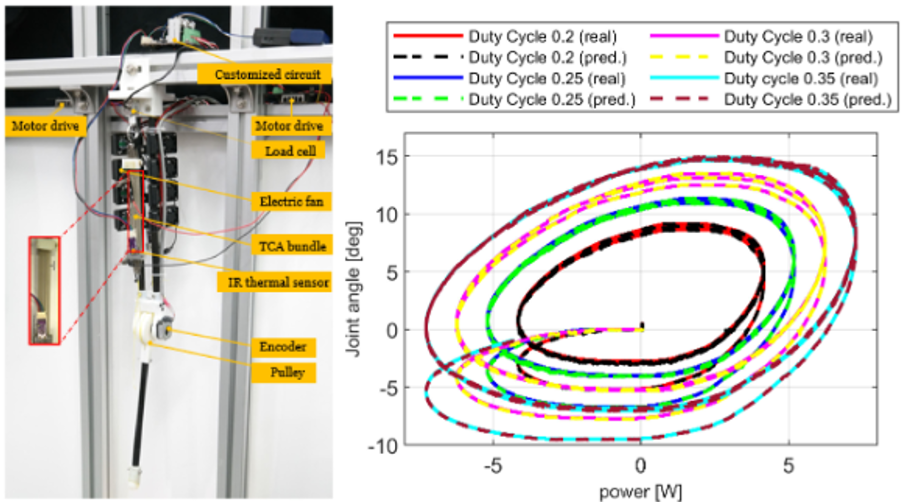
Long short term memory model based position-stiffness control of antagonistically driven twisted-coiled polymer actuators using model predictive control
Tuan Luong, Kihyeon Kim, Sungwon Seo, Jeongmin Jeon, Chanyong Park, Myeongyun Doh, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
IEEE Robotics and Automation Letters, 2021
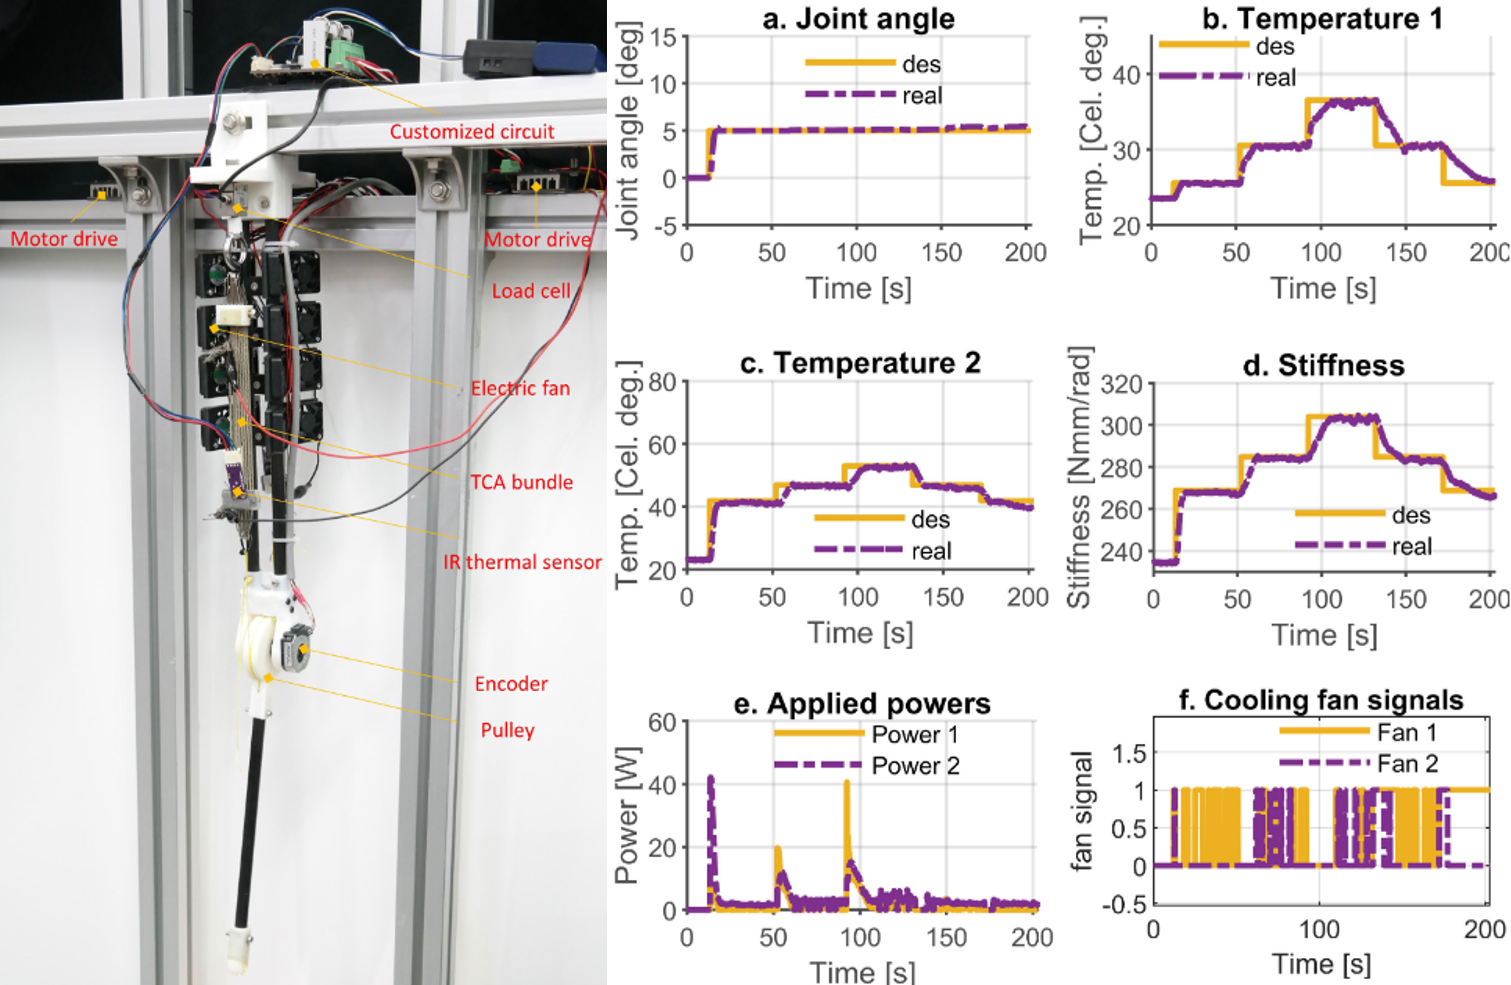
Realization of a simultaneous position-stiffness controllable antagonistic joint driven by twisted-coiled polymer actuators using model predictive control
Tuan Luong, Sungwon Seo, Kihyeon Kim, Jeongmin Jeon, Francisco Yumbla, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
IEEE Access, 2021
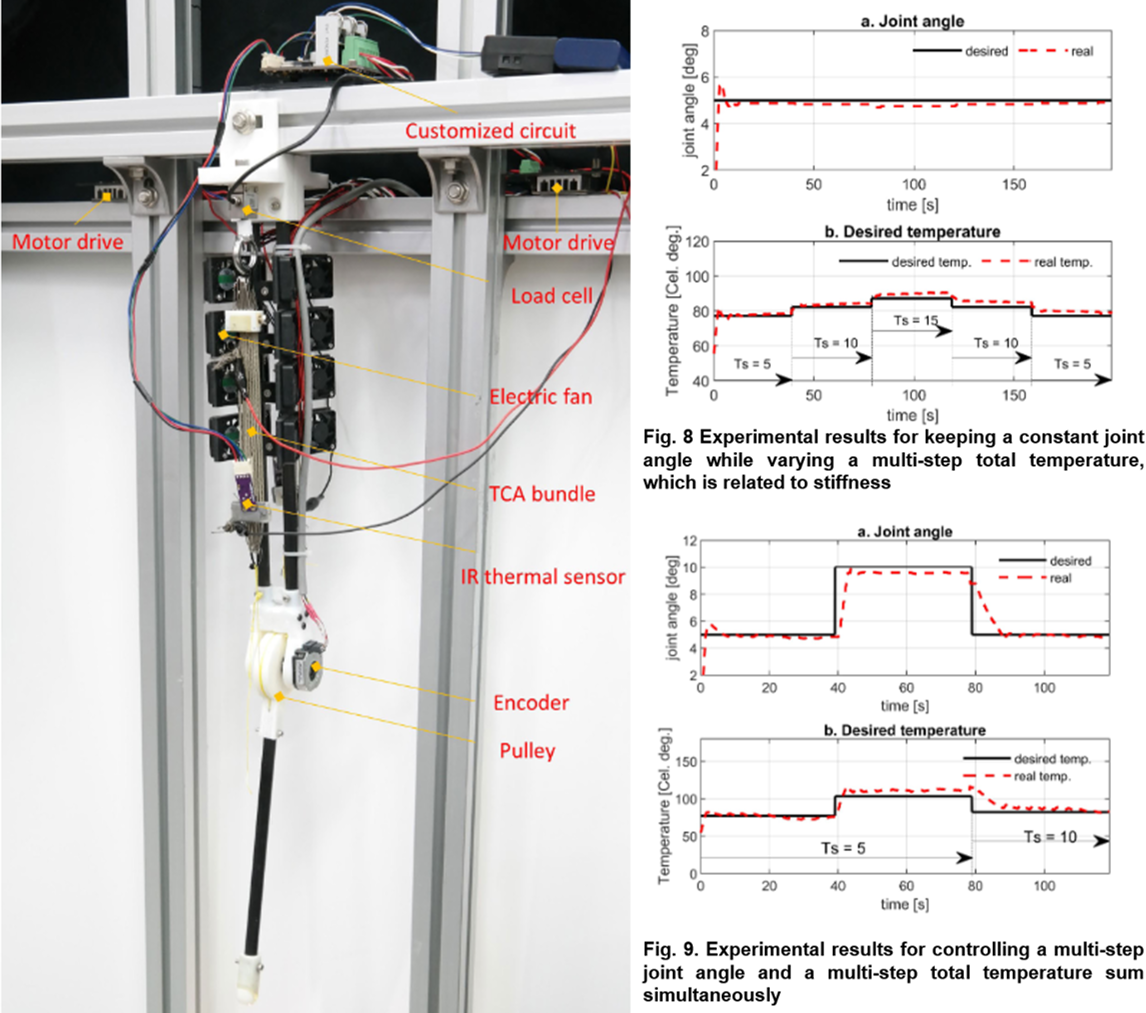
Simultaneous position-stiffness control of antagonistically driven twisted-coiled polymer actuators using model predictive control
Tuan Luong, Kihyeon Kim, Sungwon Seo, Jeongmin Jeon, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020
Electron tunneling of hierarchically structured silver nanosatellite particles for highly conductive healable nanocomposites
Daewoo Suh, KP Faseela, Wonjoon Kim, Chanyong Park, Jang Gyun Lim, Sungwon Seo, Moon Ki Kim, Hyungpil Moon, Seunghyun Baik
Nature Communications, 2020
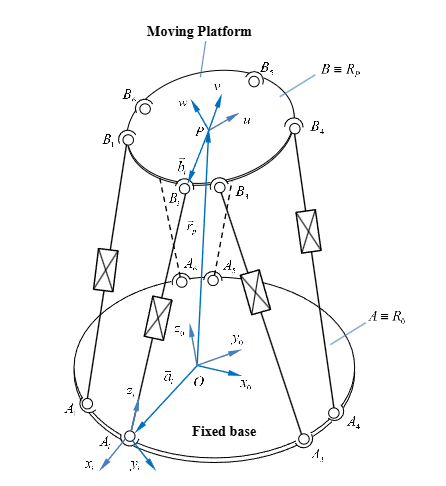
An Adaptive Backstepping Terminal Sliding Mode Control for Stewart Platforms
Tuan Anh Luong, Sungwon Seo, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
2019 16th International Conference on Ubiquitous Robots (UR), 2019
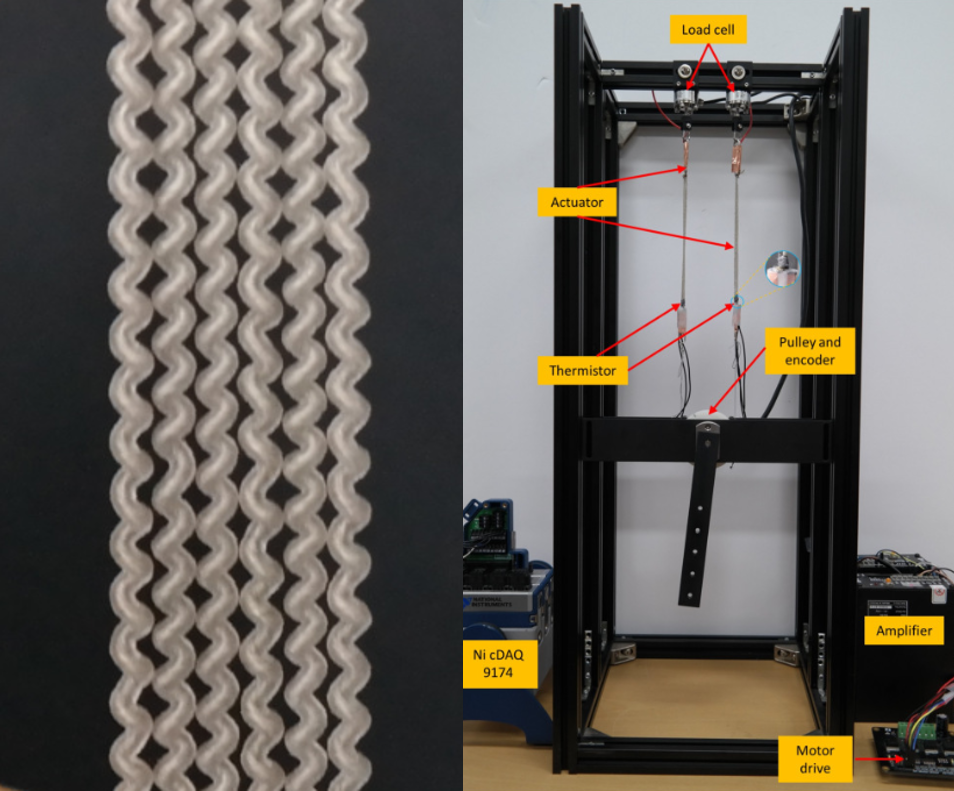
Impedance control of a high performance twisted-coiled polymer actuator
Tuan Luong, Kihyeon Kim, Sungwon Seo, Jae Hyeong Park, Youngeun Kim, Sang Yul Yang, Kyeong Ho Cho, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2018
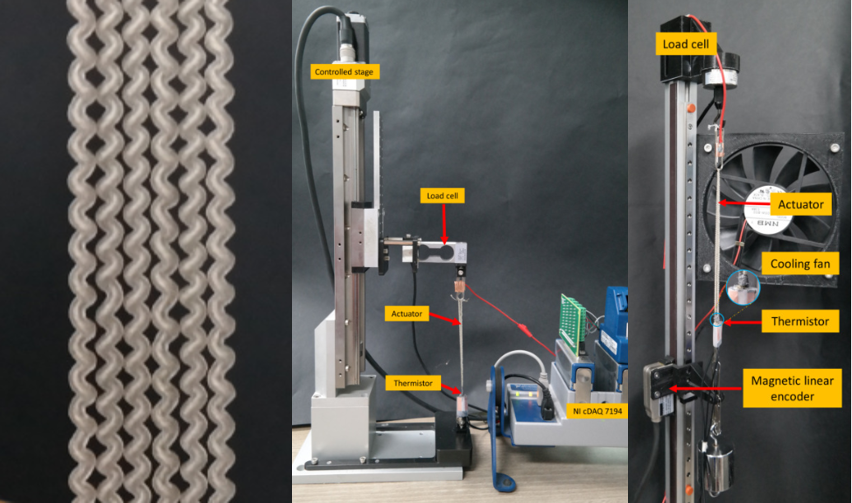
Modeling and position control of a high performance twisted-coiled polymer actuator
Tuan Luong, Kihyeon Kim, Sungwon Seo, Jae Hyeong Park, Youngeun Kim, Sang Yul Yang, Kyeong Ho Cho, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
2018 15th International Conference on Ubiquitous Robots (UR), 2018
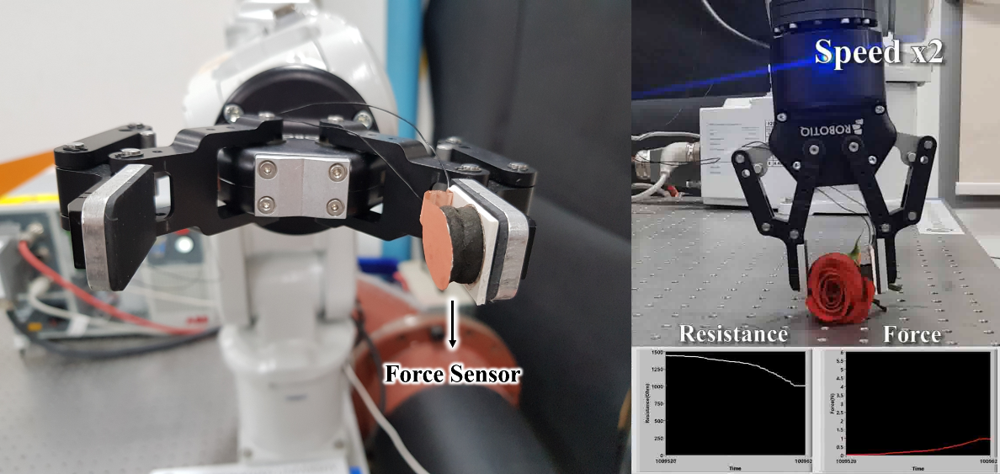
Silver nanoflower decorated graphene oxide sponges for highly sensitive variable stiffness stress sensors
Fakhre Alam Khan, C Muhammed Ajmal, Seonghyun Bae, Sungwon Seo, Hyungpil Moon, Seunghyun Baik
Small, 2018
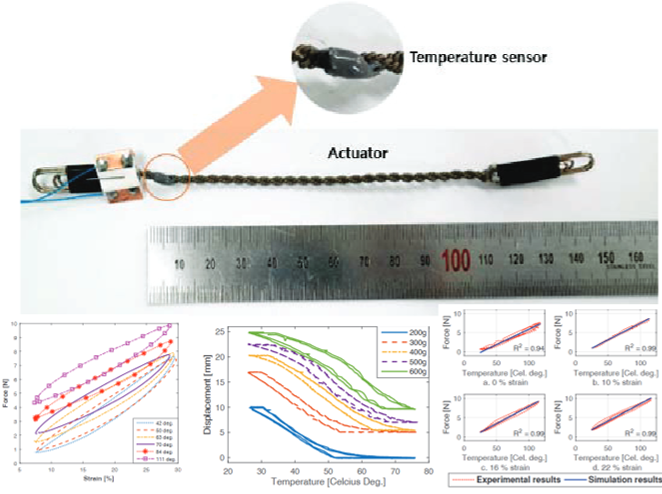
Differential hysteresis modeling with adaptive parameter estimation of a super-coiled polymer actuator
Tuan Anh Luong, Sungwon Seo, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
2017 14th International Conference on Ubiquitous Robots and Ambient Intelligence (URAI), 2017
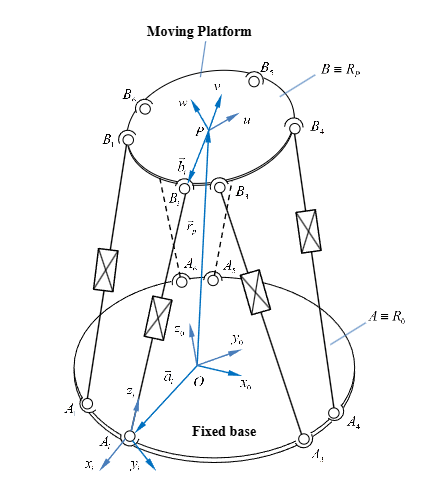
Continuous terminal sliding mode control with perturbation estimation for a stewart platform
Tuan Anh Luong, Sungwon Seo, Jeongmin Jeon, Jeongyeol Park, Ja Choon Koo, Hyouk Ryeol Choi, Hyungpil Moon
2017 14th International Conference on Ubiquitous Robots and Ambient Intelligence (URAI), 2017
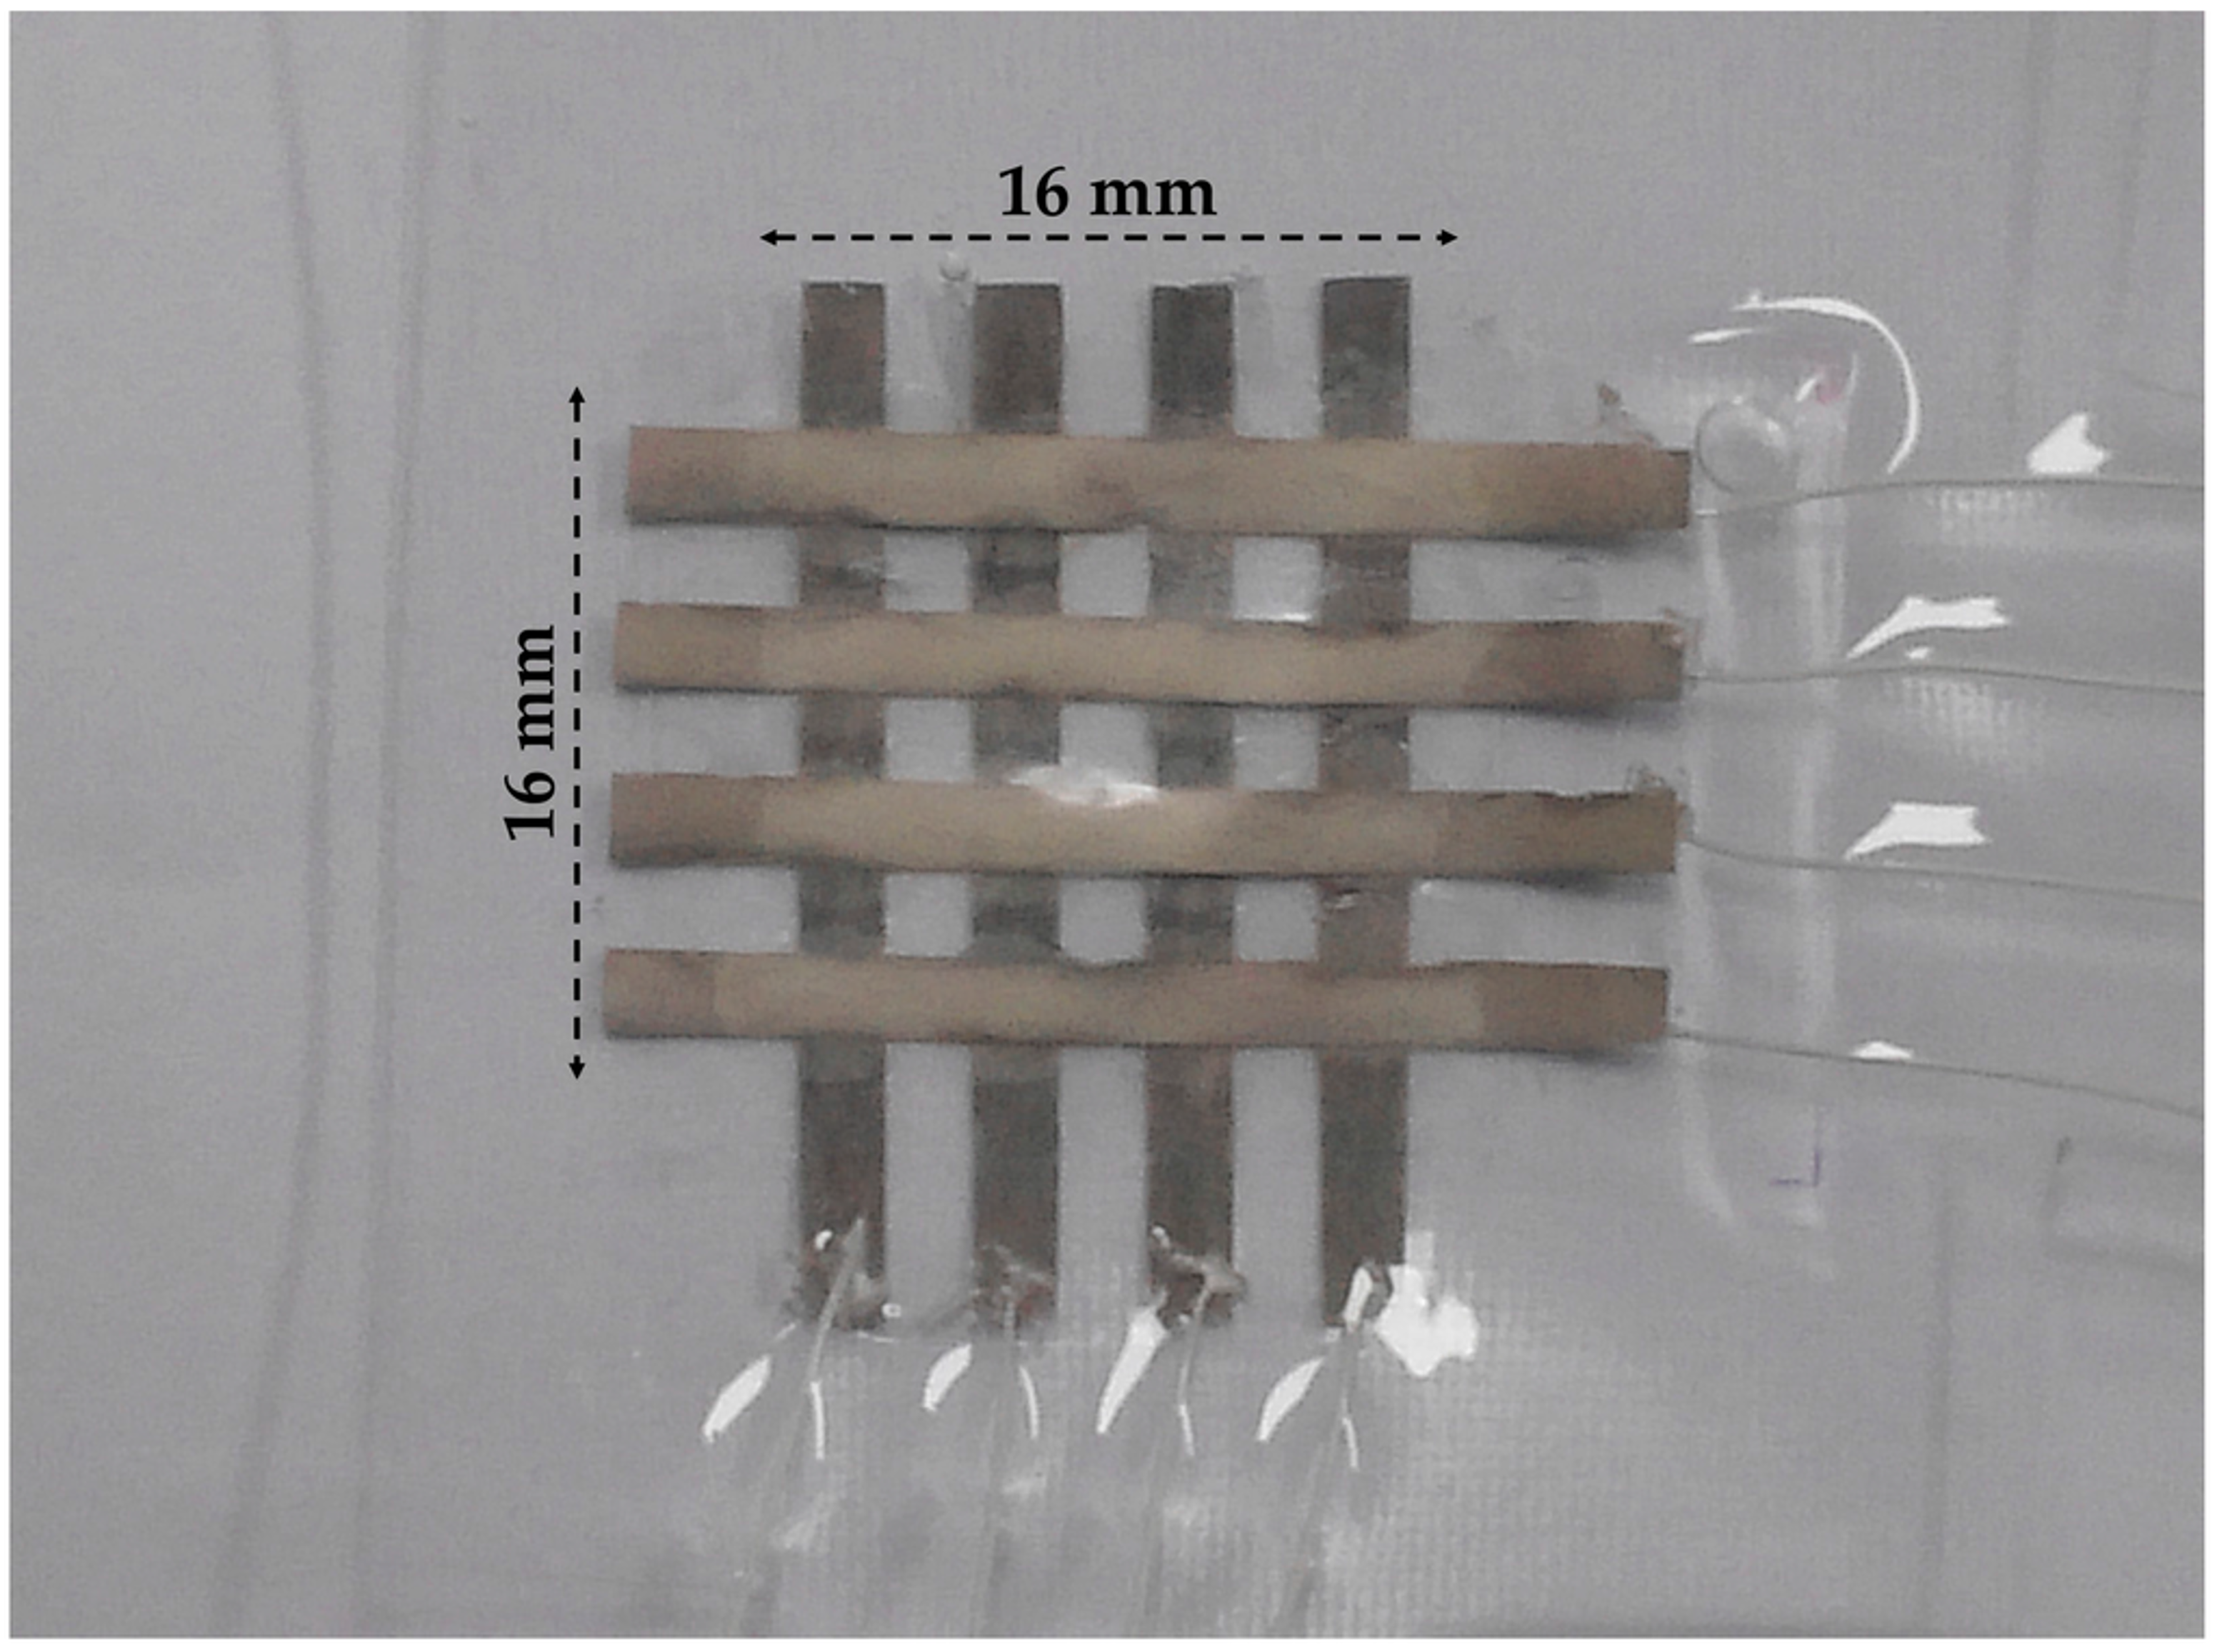
Flexible touch sensors made of two layers of printed conductive flexible adhesives
Sungwon Seo, Seonggi Kim, Jiyeon Jung, Rujun Ma, Seunghyun Baik, Hyungpil Moon
Sensors, 2016
Research Projects
Development of service robot technologies for cleaning a table
2022 – 2025
- Developed learning-based non-prehensile manipulation methods for robotic table-cleaning tasks
Development of cloud robot intelligence augmentation, sharing and framework technology to integrate and enhance the intelligence of multiple robots
2020 – 2023
- Developed deep learning-based grasp pose estimation methods
- Designed a hybrid gripper capable of switching between two-finger grasping and vacuum suction
Development of manipulation technologies in social contexts for human-care service robots
2019 – 2020
- Developed stable pushing and motion planning methods for non-prehensile object manipulation
Development of biomimetic artificial muscle actuator
2016 – 2019
- Designed and fabricated flexible tactile and stretchable strain sensors for prosthetic hands
- Designed STM32-based hardware controllers and sensing circuits for artificial muscle actuators
- Developed a characterization testbed for artificial muscle modeling
Education
- B.S. in Mechanical Engineering, Sungkyunkwan University, 2016
Teaching Assistant
- Fall 2018: Design Laboratory on Vibration and Dynamic Systems (EME3057), Sungkyunkwan University
- Fall 2017: Design Laboratory on Vibration and Dynamic Systems (EME3057), Sungkyunkwan University
- Spring 2017: Kinematics of Machinery (EME3017), Sungkyunkwan University
- Fall 2016: Design Laboratory on Vibration and Dynamic Systems (EME3057), Sungkyunkwan University
- Spring 2016: Design Laboratory on Vibration and Dynamic Systems (EME3057), Sungkyunkwan University
Reviewer
- IEEE Transactions on Robotics (T-RO)
- IEEE Transactions on Industrial Electronics (TIE)
- IEEE International Conference on Automation Science and Engineering (CASE)